Charan Tej

Charan Tej

UAV Design Engineer — Defence & Aerospace Systems

I design, integrate, and flight-test UAV systems — airframes, structures, and harnesses across cargo, eVTOL, fixed-wing, and blended-wing-body platforms. Three years in, from concept through to the flight line.

Open to new roles · 30-day notice · Bengaluru, India

Selected work

Projects

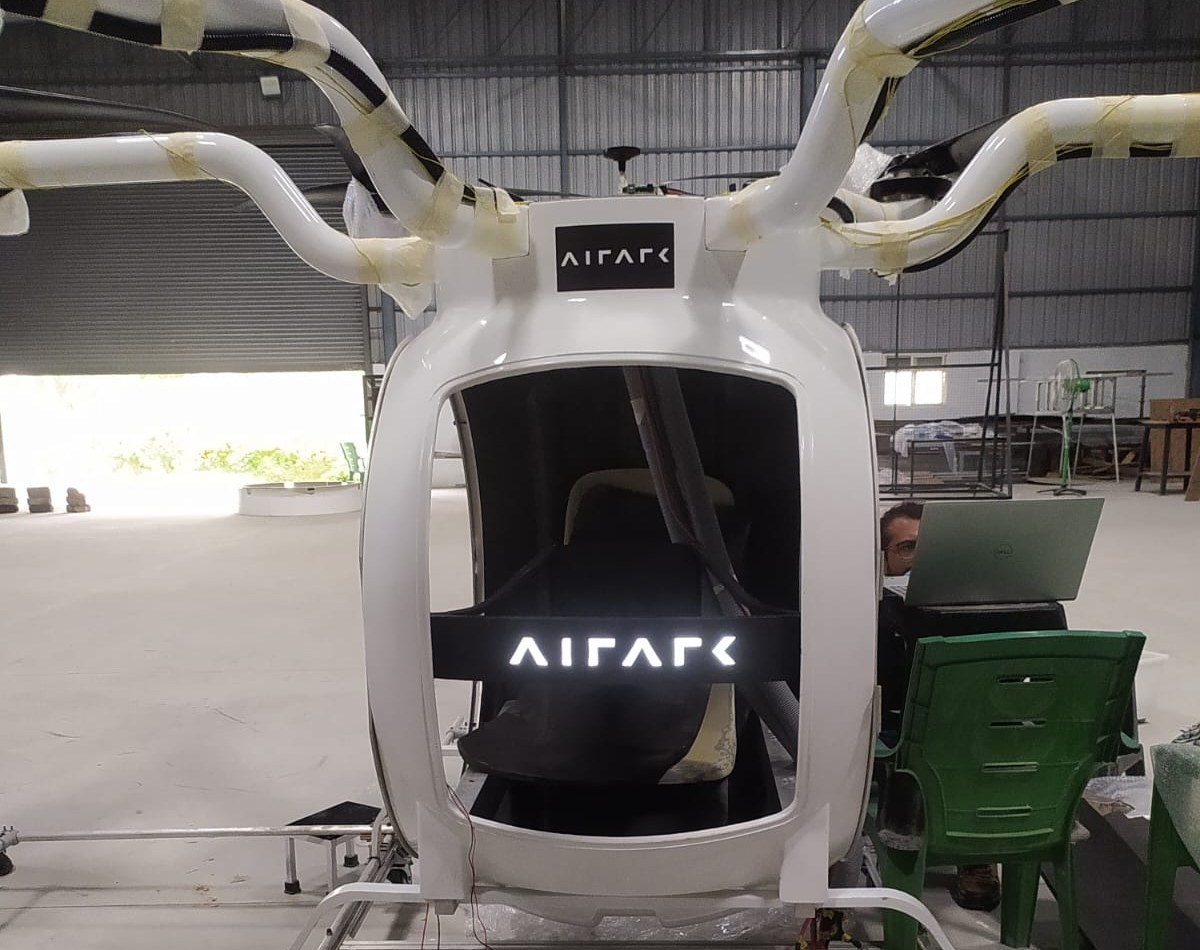
Single-passenger eVTOL during systems integration
Systems integration
Flight test

Single-Passenger eVTOL — Systems Integration

AirArk Space Technologies · 2023 – 2025

Systems-integration lead on a 250 kg MTOW single-passenger eVTOL — harness architecture, propulsion validation, and airworthiness inspection across flight campaigns.

  • Systems integration of the full-scale eVTOL, with electrical harness architecture for propulsion validation.
  • 50+ airworthiness inspections with zero safety incidents across flight operations.
  • Coordinated pre-flight and post-flight inspection protocols for every mission.

MTOW 250 kg  ·  Config Single-passenger eVTOL  ·  Record 50+ insp. / 0 incidents
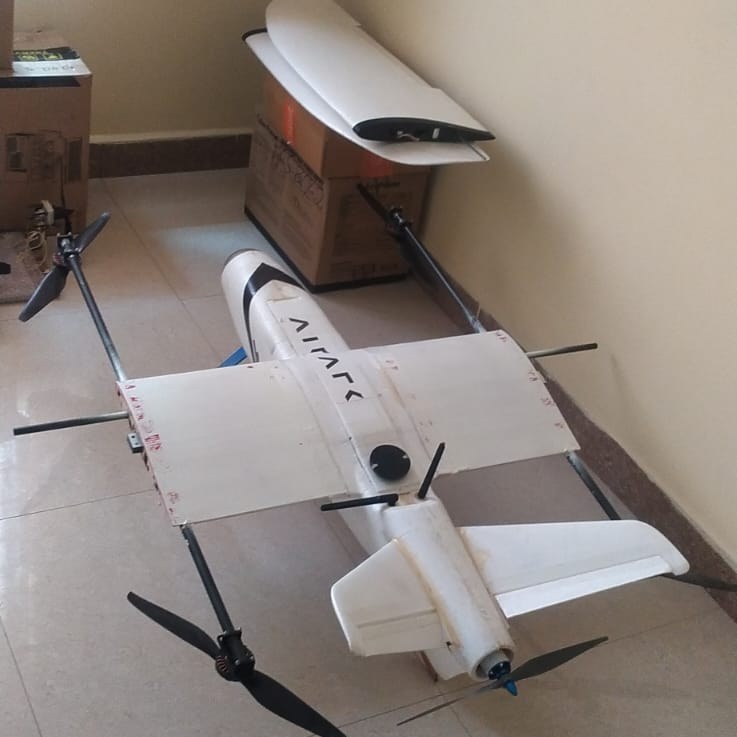
Fixed-wing VTOL UAV
Fixed-wing VTOL UAV
Flight test

Fixed-Wing VTOL UAV — Surveillance

Design study · XFLR5 + CFRP

Quad-motor VTOL fixed-wing UAV for endurance surveillance — sized from constraint analysis through CFRP spar structural sizing and full manufacturing documentation.

  • NACA 4412 wing, AR 8, 2.04 m span — validated via XFLR5 polar at operating Reynolds number.
  • CFRP spar sized to ultimate load — bending, shear, and deflection verified.
  • Complete drawing set with GD&T, BOMs, and composite layup documentation.

MTOW 4.5 kg  ·  Span 2.04 m (AR 8)  ·  Endurance 90 min (target)

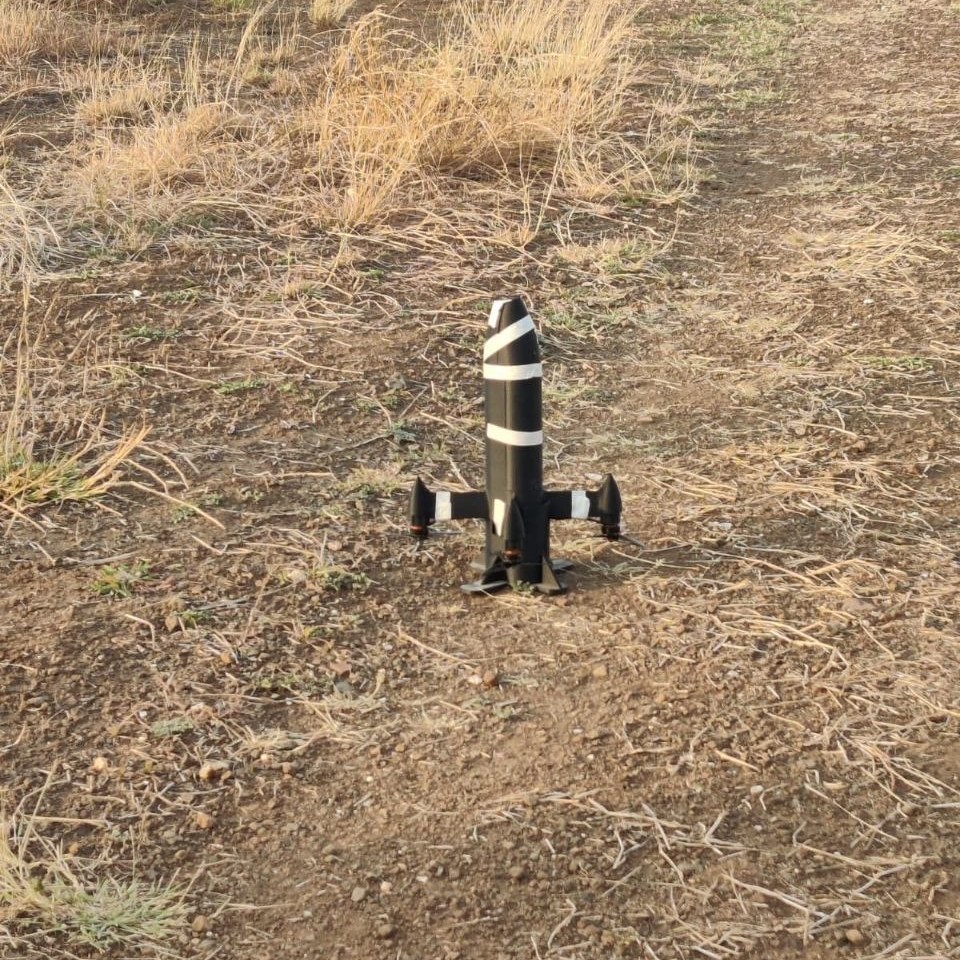
High-speed interceptor UAV
Flight / test

High-Speed Interceptor UAV

Golden Pearl Defense Systems · 2025 – 2026

Airframe and structural design of a high-speed interceptor UAV for defence applications — fuselage optimisation for CG alignment and drag reduction, across multi-rotor and fixed-wing configurations.

  • Contributed to airframe and structural design and optimisation for structural integrity and weight distribution.
  • Fuselage optimisation based on volumetric and CG alignment for drag reduction.
  • Cross-functional work with avionics, propulsion, and software teams on system integration.

Config Multi-rotor + fixed-wing  ·  Role Airframe / structural  ·  Detail Under NDA

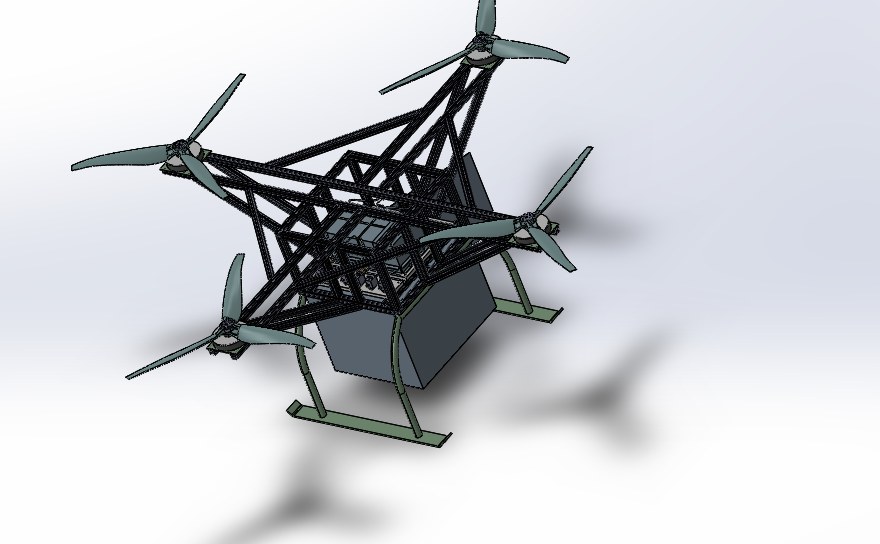
Heavy-lift cargo UAV — CAD render
CAD — airframe

Heavy-Lift Cargo UAV — 250 kg MTOW

AirArk Space Technologies · 2023 – 2025

Airframe structural integration and propulsion characterisation for a heavy-lift cargo UAV, including thrust-stand testing across the operational range.

  • Structural integration of the airframe assembly to operational safety compliance.
  • Designed and tested thrust-stand setups (20 / 500 / 1000 kg load cells) for motor–propeller characterisation.
  • Technical documentation for propulsion selection and flight-control integration.

MTOW 250 kg  ·  Load cells 20 / 500 / 1000 kg  ·  Role Structural integration

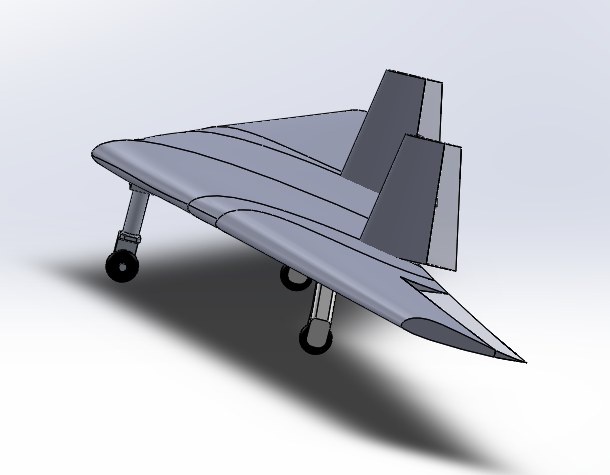
BWB UAV — CAD render (VAYU Aero)
CAD — concept

Blended-Wing-Body Cargo UAV

VAYU Aero · 2026 – present

Airframe and structural design of a blended-wing-body cargo platform — developing the structural architecture and load paths, and balancing mass distribution against performance targets.

  • Developed BWB airframe and structural assemblies for a cargo mission profile.
  • Defined internal load paths and structural members for integrity under operating loads.
  • Coordinated structural layout with propulsion and avionics packaging.

Config BWB cargo  ·  Role Structural / airframe  ·  CAD SolidWorks

Autonomous Solar-Panel Cleaning Robot

Personal / academic · 2024 – 2025

Autonomous ground robot that clears dust and debris from solar panels without surface damage — mechanical design, a custom transmitter, and LiDAR-based navigation, field-validated across conditions.

  • Designed the mechanical structure via rapid FDM prototyping for field durability.
  • Designed a custom remote controller (transmitter) and integrated LiDAR for obstacle detection and navigation.

Type Autonomous ground robot  ·  Nav LiDAR + RC  ·  Build FDM

Supersonic CD Nozzle — Acoustic & Flow Analysis

B.Tech thesis · SASTRA University · 2023

Acoustic and aerodynamic study of Mach 1.6 convergent–divergent nozzles with chevron configurations, tested in a wind tunnel using Schlieren and shadow visualisation.

  • Designed and manufactured Mach 1.6 CD nozzles with 8- and 12-chevron slant-edge configurations.
  • Flow visualisation across pressure ratios 1.25–3.75; MATLAB image processing and acoustic benchmarking vs a baseline.

Mach 1.6  ·  Pressure ratio 1.25–3.75  ·  Method Schlieren + MATLAB

Where I've worked

Experience

Jul 2026 — Present

Sr. UAV Design Engineer · current

VAYU Aero · Bengaluru

  • Leading conceptual and preliminary design of multi-rotor and fixed-wing (BWB) cargo UAVs for heavy-lift logistics.
  • Designing and optimising airframe and structural assemblies for octocopter, quadcopter, and BWB configurations.
  • Market research and technical feasibility on emerging BWB platforms — CTOL vs VTOL for future cargo integration.
Oct 2025 — Jun 2026

UAV Design Engineer

Golden Pearl Defense Systems · Mhow

  • Contributed to airframe and structural design of a high-speed interceptor UAV program for defence applications.
  • Fuselage optimisation for CG alignment and drag reduction; structural assemblies for integrity and weight distribution.
  • Collaborated across avionics, propulsion, and software teams on system integration requirements.

Program specifics covered by confidentiality — discussed on request within permitted limits.

Aug 2023 — Oct 2025

UAV Design Engineer

AirArk Space Technologies · Hyderabad

  • Led structural integration of airframe assemblies for a 250 kg MTOW cargo UAV to operational safety compliance.
  • Performed systems integration of a 250 kg MTOW single-passenger eVTOL — 50+ airworthiness inspections, zero incidents.
  • Designed electrical harness architectures and thrust-stand setups (20 / 500 / 1000 kg load cells).
  • Authored technical documentation on autopilot and flight-control-system selection.
Nov 2022 — Dec 2022

Drone Intern

Brahmastra R&D Center · Remote

  • Structured training in multi-rotor UAV integration and assembly; hands-on Mission Planner for autonomous missions.

What I work with

Skills

CAD & design
SolidWorks, ANSYS SpaceClaim, Design Modeler, DFM, DFA, wire-harness routing, reverse engineering
Analysis
XFLR5, ANSYS Workbench, FEA, structural hand calculations, QPROP / QMIL, basic CFD
Manufacturing
GD&T, BOMs, FDM & SLA printing, CNC machining, laser cutting, sheet metal, CFRP
Flight systems
Mission Planner, PX4, Pixhawk Cube Orange, Kakute H7, autopilot integration
Integration & test
Airworthiness inspection, thrust-stand testing, harness design, CG analysis, pre / post-flight checks

Get in touch

Open to UAV design, defence aerospace, and systems-integration roles — available within 30 days.

Charanhari994@gmail.com Bengaluru, India B.Tech Aerospace — SASTRA